2026
Journal article
Published
Real-Time HRI: Human Hand Gesture Mapping for 7-DoF Robotic Arm Operation
Concurrency and Computation: Practice and Experience · Vol. 38, Issue 6, e70643 · Open access
University of BrightonAI Robotics Lab
Dr Sajjad Hussain
Lecturer in Robotics, Automation and Control Engineering
Brighton, United Kingdom
I am a Lecturer and Robotics & AI Researcher at the University of Brighton. My work explores how robotic systems can perceive human gestures, understand natural language, plan actions and interact safely with the physical world.
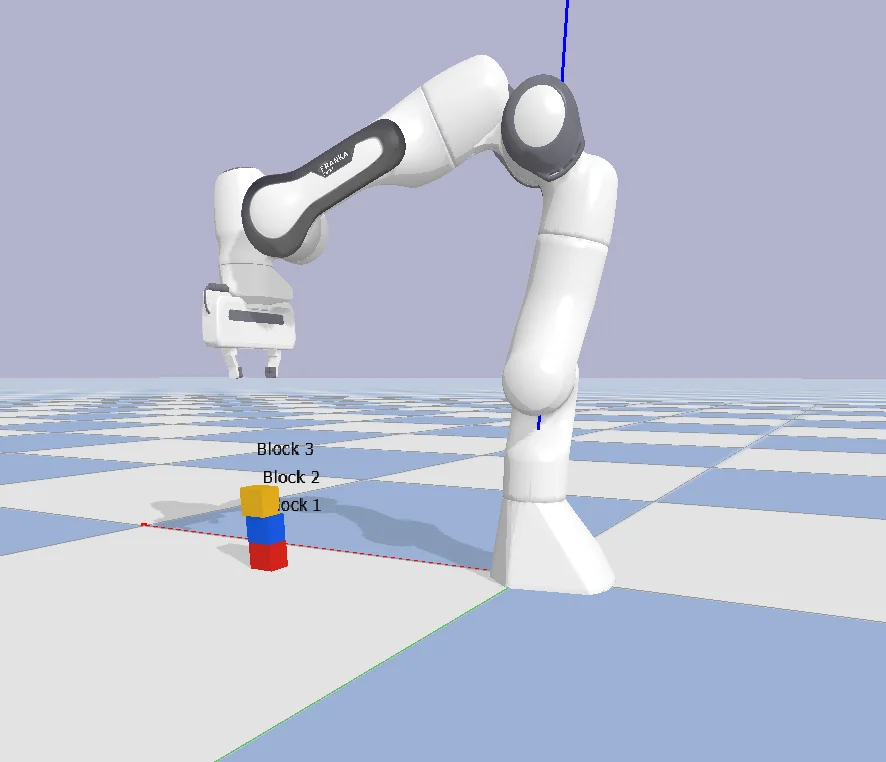
Hand landmarks are tracked, interpreted and turned into motion on a 7-DoF arm — the loop behind AI-RTGM and my body-pose control work.
01Research
My research sits where human perception meets robot control. I build systems that turn what people do and say — a hand gesture, a body movement, a spoken instruction in English or German — into safe, executable motion on a 7-DoF Franka Emika Panda. The work combines learned perception, language models and classical robotics: kinematics, trajectory generation, motion planning and compliant control.
Research themes and case studies02Flagship work
Each project links the published result to the system that produced it — and says plainly whether it ran on a physical robot or in simulation.
03Publications
Journal articles, conference papers and preprints in human–robot interaction, language-driven manipulation and motion planning.
2026
Journal article
Concurrency and Computation: Practice and Experience · Vol. 38, Issue 6, e70643 · Open access
2025
Review
SN Computer Science · Vol. 6, Article 588 · Springer Nature
2025
Conference
IEEE International Conference on Advanced Robotics and Mechatronics (ICARM 2025) · IEEE ICARM 2025 · pp. 452–457 · Portsmouth, UK
2025
Conference
First German Robotics Conference, Nuremberg · Peer-reviewed conference abstract · full text on arXiv
2025
Conference
IEEE International Conference on Emerging Technologies and Innovation for Sustainability (EmergIN 2025) · IEEE EmergIN 2025 · pp. 886–890
04Highlights
Abu Dhabi AI-Robotics Conference (AIRoC) 2025 — Dialogue on Humanoids
Invited talk on combining gesture recognition and language models for intuitive control of collaborative manipulators, at a conference organised by the Robotics Department of Mohamed bin Zayed University of Artificial Intelligence (MBZUAI).
University of Brighton · June 2026
About the thesisUniversity of Brighton · from September 2026
Teaching1–4 July 2026
18th International Conference on Social Robotics (ICSR + ART 2026)
University of London, London, United Kingdom
International Conference on Social Robotics — ICSR + ART 2026
1–3 August 2025
IEEE ICARM 2025
Portsmouth, United Kingdom
Multilingual NLP for 7-DoF robotic manipulation
March 2025
First German Robotics Conference
Nuremberg, Germany
Energy-efficient trajectory planning for high-DoF robots
23–26 September 2024
ICRA@40
Rotterdam, Netherlands
Gesture-based manipulation of a 7-DoF arm for multistep tasks
Collaborate
I welcome discussions on research collaboration, academic projects and the development of intelligent robotic systems, particularly in human–robot interaction, embodied AI and robotic manipulation.