Theme A
Human–Robot Interaction & Multimodal Control
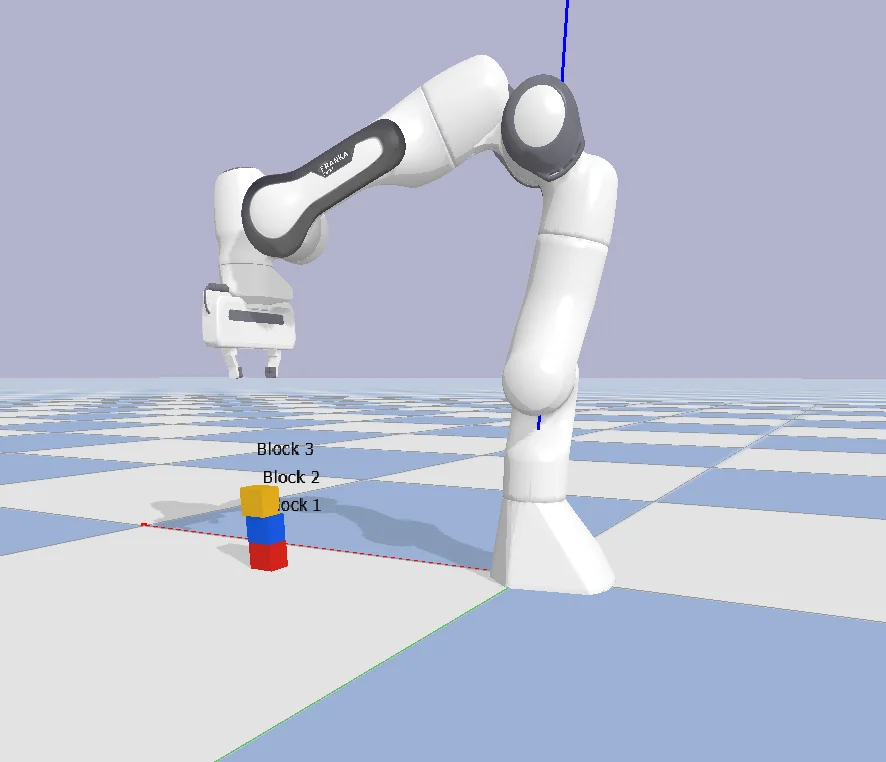
This is the core of my research. I build pipelines that track a person's hands and body in real time, recognise intent and map it onto continuous control of a 7-DoF Franka Emika Panda. The engineering challenge is less about recognition accuracy in isolation and more about the full loop: latency, calibration, dead-man safety gates, compliant motion and graceful failure when tracking drops out.
Established work
- Real-time hand-gesture recognition mapped to multistep manipulation tasks
- Body-pose teleoperation through MoveIt Servo with calibration and dead-man control
- Integration of perception with ROS 2, MoveIt 2 and the Franka control stack
Current & emerging
- Fusing gesture and speech into one interaction channel
- User studies of operator workload and trust